All projects
Project Study
Autonomous Line-Following Robot
Sensor-Based Mobile Robot
Embedded Systems
Mobile Robotics
Hardware Integration
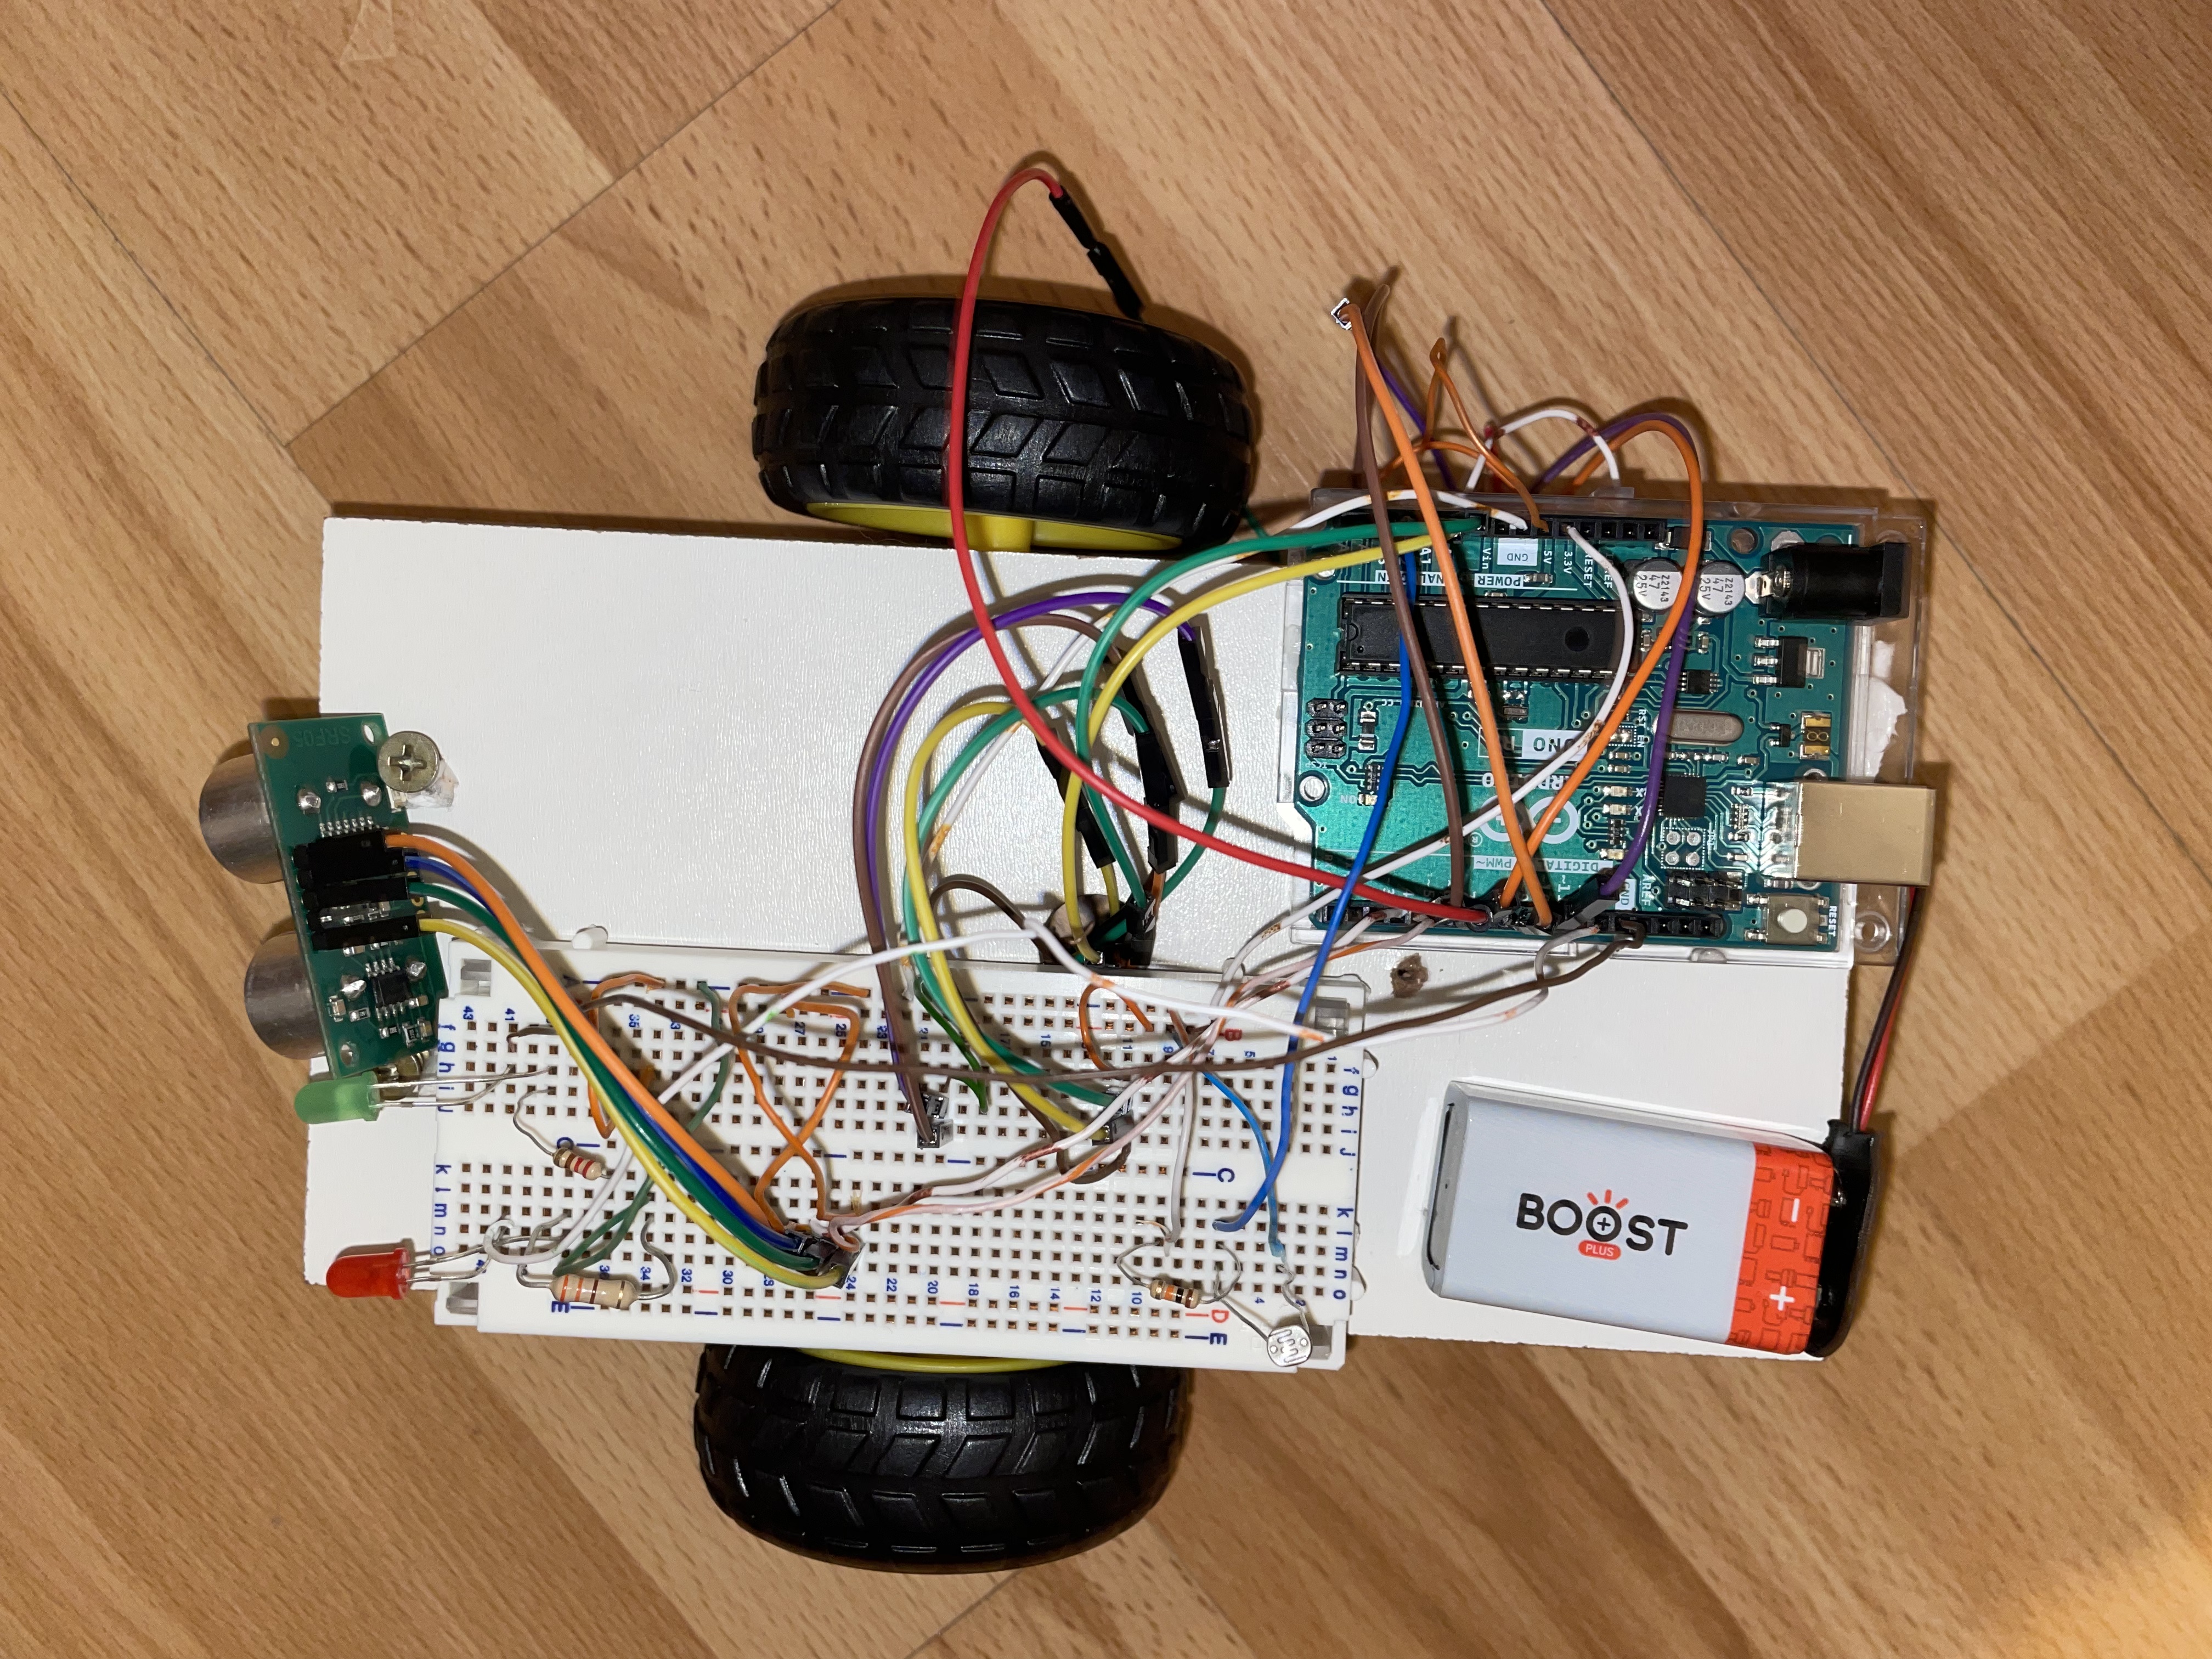
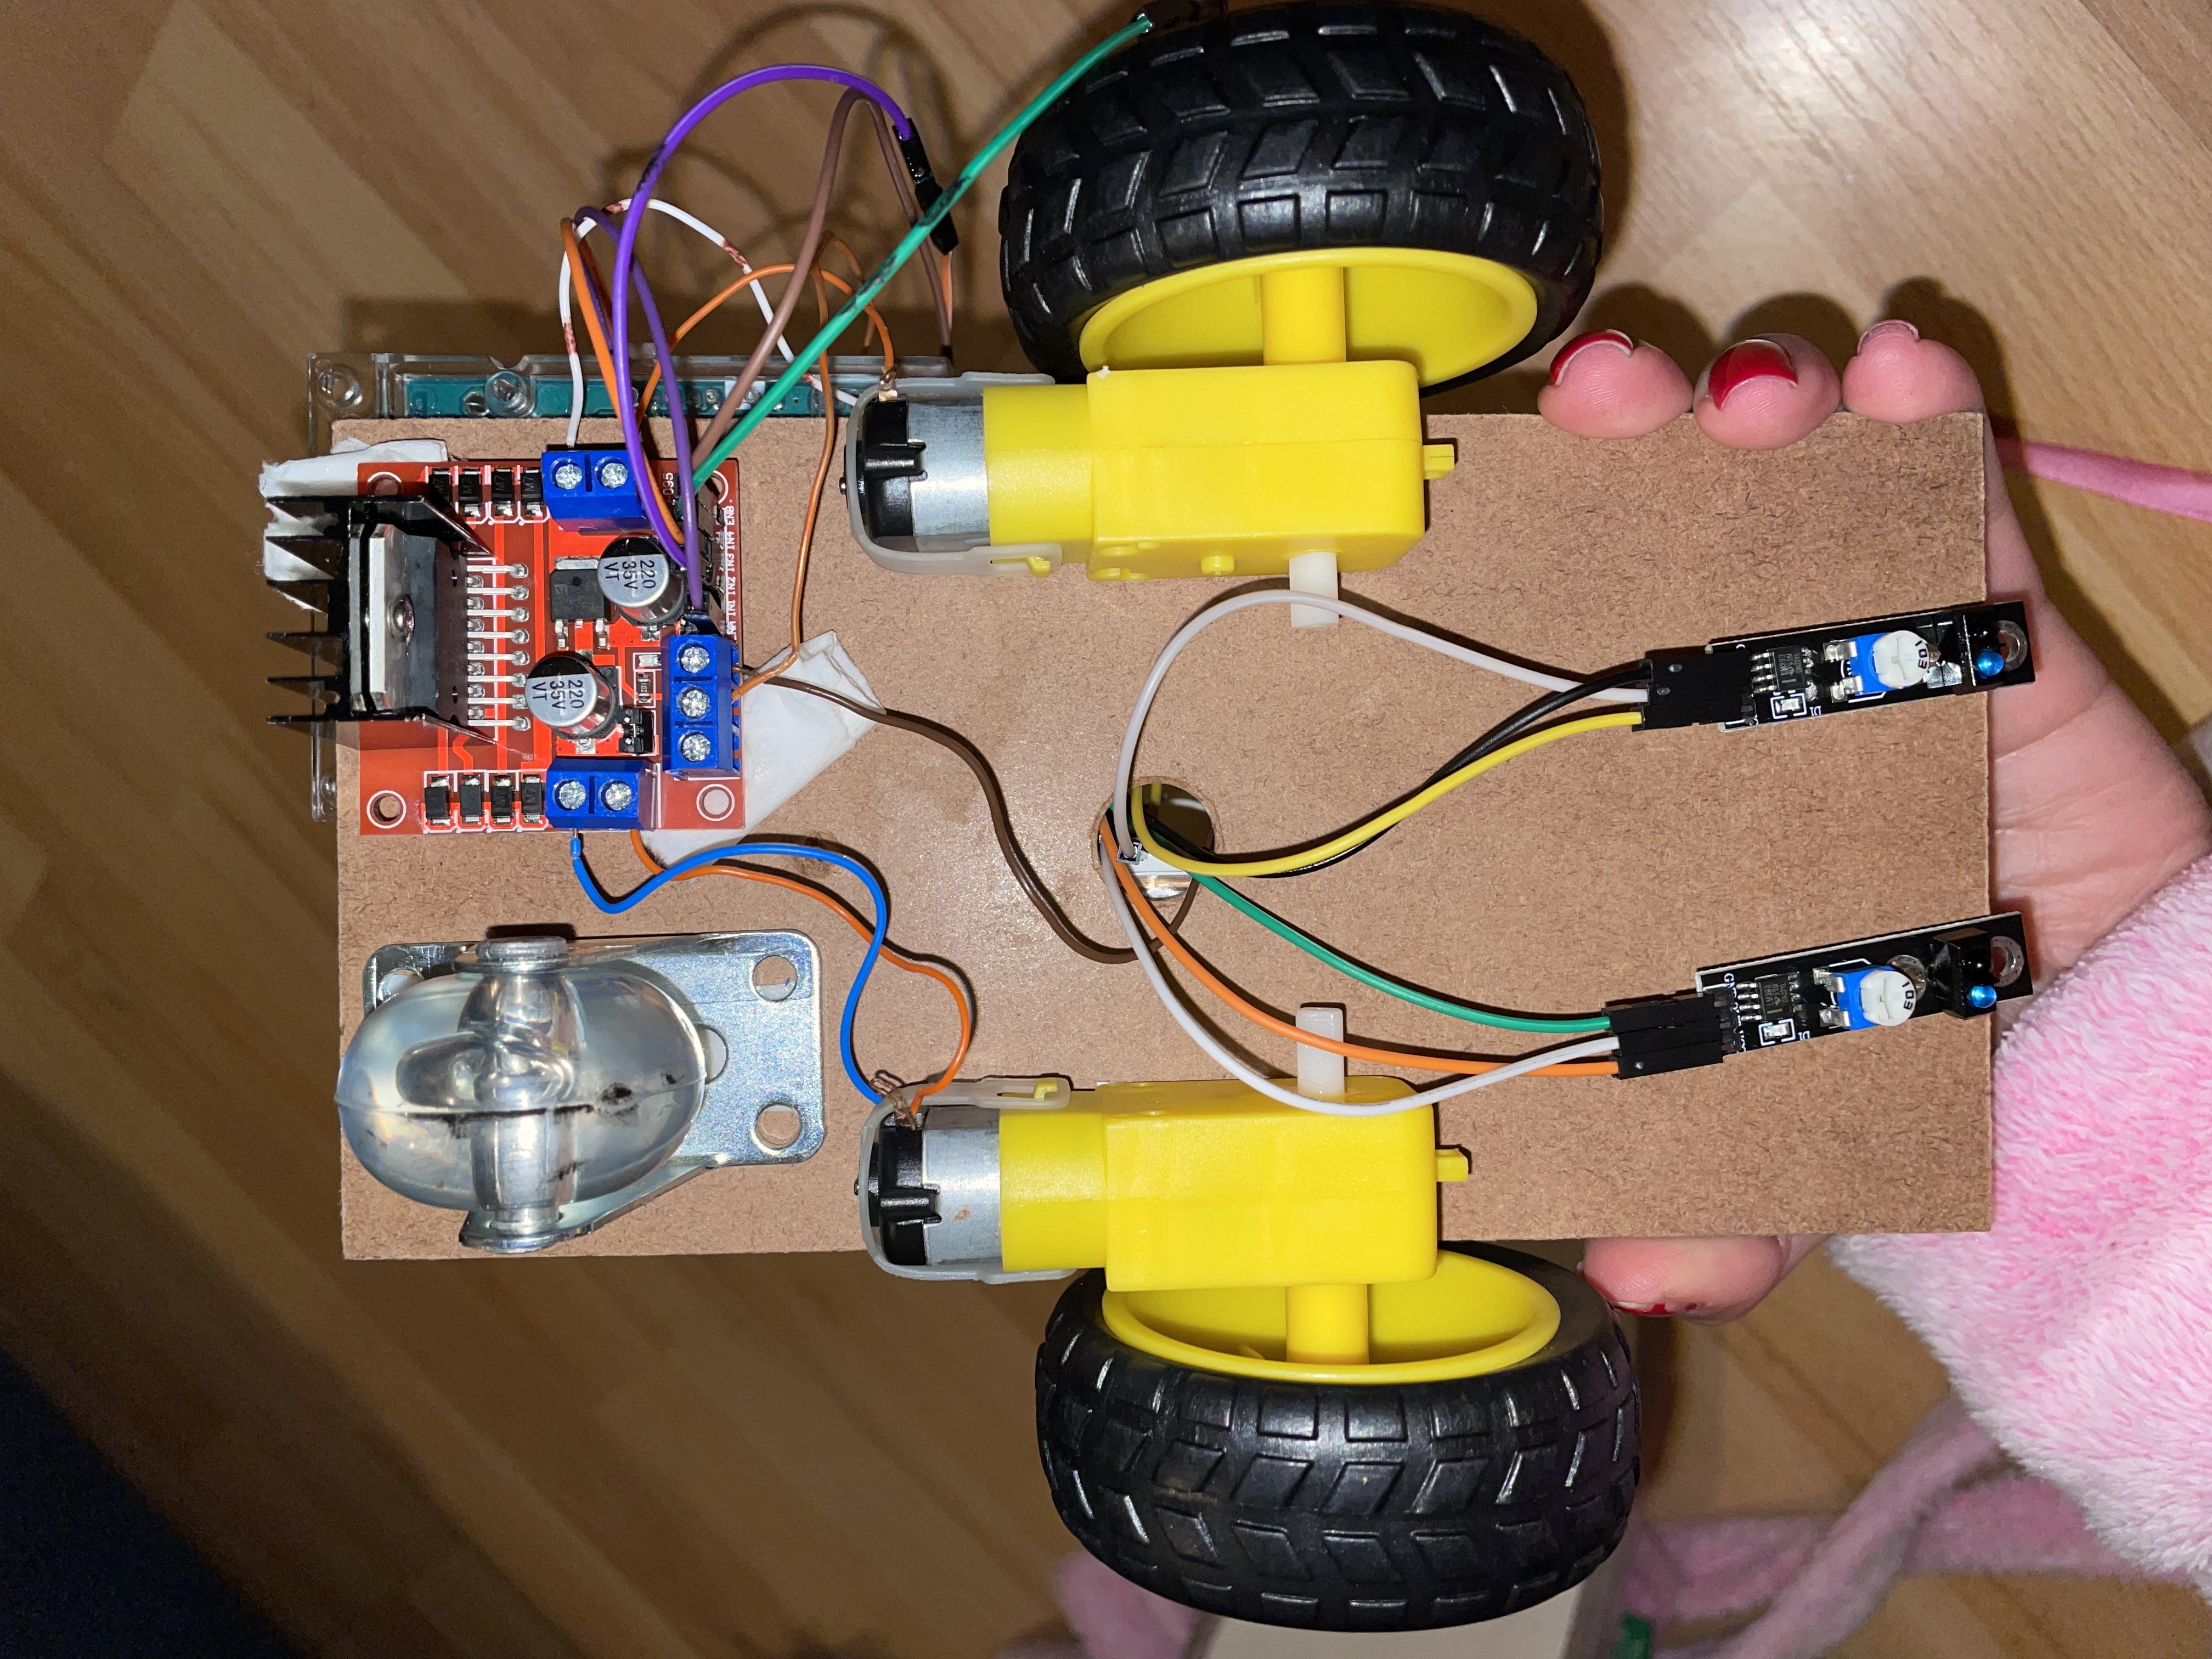
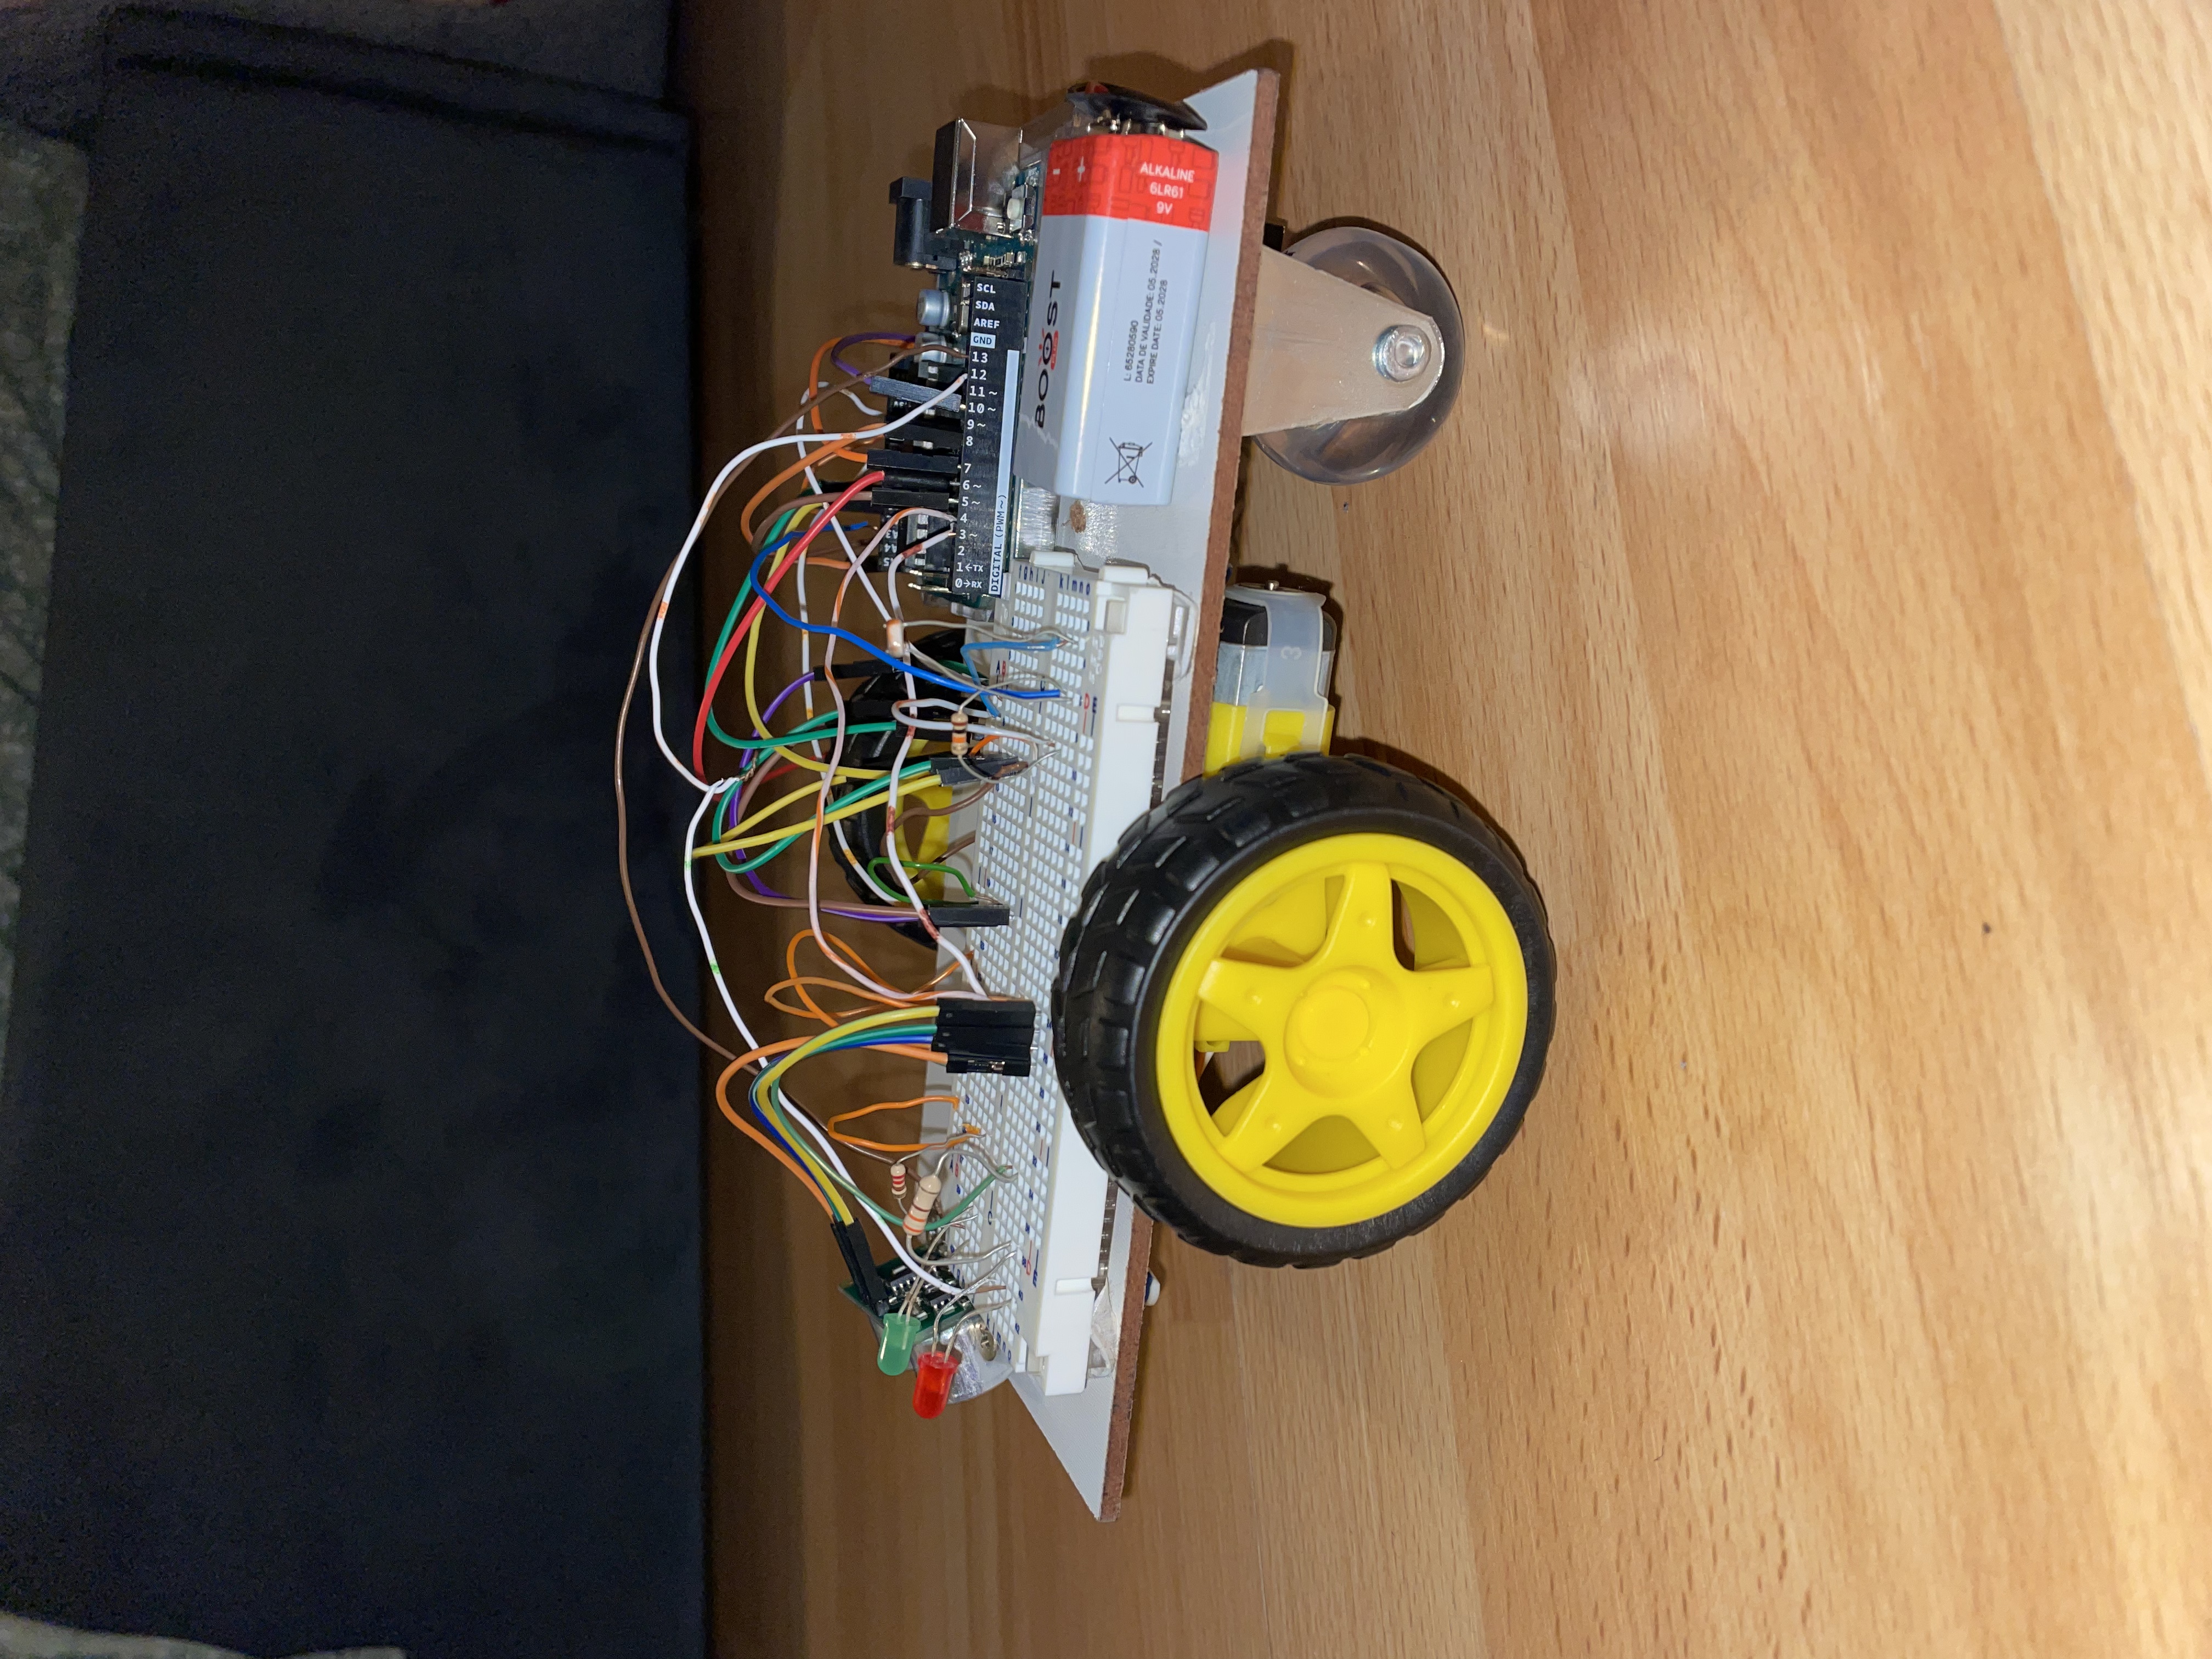
Designed and assembled a small autonomous mobile robot capable of following a line, detecting nearby obstacles and adapting its lighting according to ambient conditions.
System Overview
Architecture
- 01Line + Distance + Light Sensors
- 02Arduino Control Logic
- 03H-Bridge + PWM
- 04Motors + Lighting
Technical Details
My Contribution
The project’s strongest area was physical integration and electronic assembly, supported by straightforward embedded control logic.
- Electronic assembly and wiring
- Integration of line-following sensors
- Ultrasonic obstacle detection
- DC motor control
- H-bridge motor driver integration
- PWM speed control
- LDR ambient-light sensing
- LED control
- Embedded control logic in C/C++
- Testing and calibration
Technical Toolkit
Technologies
Arduino
C/C++
IR Sensors
Ultrasonic Sensor
LDR
DC Motors
PWM
Embedded Systems